- sale@instructrobot.com
- Dallas, TX , United States

Soft robotics is an engineering field that builds machines with flexible, deformable bodies. Unlike traditional robots, these systems may use silicone, rubber, fabric, or elastic polymers. Their bodies can bend, stretch, twist, and compress during movement. This physical softness helps them interact more safely with people and delicate objects. A soft gripper, for example, can gently hold a peach without leaving deep marks. It may also grasp objects with irregular shapes more effectively than rigid fingers.
How does soft robotics work? Engineers combine compliant materials with air chambers, fluidic actuators, tendons, magnets, or smart materials. Pumped air can expand selected chambers, creating controlled bending. Sensors then measure pressure, position, contact, or strain. A controller adjusts the input, allowing the robot to respond to changing conditions. In rehabilitation devices, this process may support a patient’s hand while limiting excessive force. In agriculture, soft grippers can handle tomatoes, leaves, and other fragile produce.
The concept sounds simple.
The engineering is not.
Flexible materials can reduce accuracy, lose strength, or wear after repeated movement. Their behavior also changes with temperature, pressure, and manufacturing differences. Engineers must test prototypes carefully rather than trust attractive demonstrations. Reliable designs require material testing, safe control systems, clear performance measurements, and practical maintenance plans. Soft robotics offers remarkable possibilities, but it is not a universal replacement for rigid machines. Its value depends on matching flexibility to a real task, measuring limitations honestly, and improving designs through repeated, evidence-based testing.
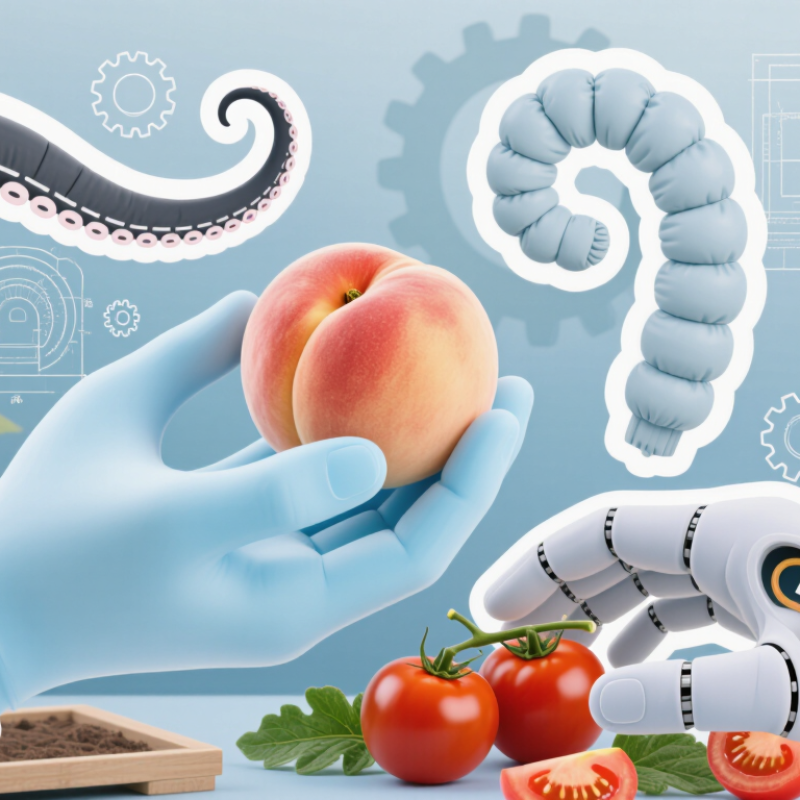
Soft robotics describes machines built from flexible materials rather than rigid metal links. Their bodies may use silicone, elastomers, textiles, or compliant polymers. These materials deform when exposed to air pressure, cables, electrical fields, or embedded shape-memory components. The machine does not simply rotate around fixed joints. It bends, stretches, twists, and adapts to contact.
Its core principle is compliance. A soft gripper can wrap around a tomato, while a rigid claw may crush it. Distributed sensing provides another foundation. Pressure cells, strain sensors, and vision systems help estimate shape and contact force. Control software then connects these signals with movement. According to the International Federation of Robotics’ World Robotics 2024 report, 541,302 industrial robots were installed globally in 2023. This figure shows the scale of automation, but soft systems address a different problem: safe, uncertain, human-centered interaction.
Energy efficiency also matters. Pneumatic systems can create gentle motion, yet compressors may consume substantial power. Electronic actuation can improve portability, but it often increases design complexity. The industry still lacks one universal testing method for durability, grip force, and lifetime. That weakness matters. IDTechEx’s Soft Robotics 2023–2033 analysis identifies healthcare, logistics, and agricultural handling as major application areas. However, forecasts are not guarantees. Material fatigue, slow response, and difficult calibration remain practical barriers. In real testing, a prototype may hold a delicate object perfectly once, then lose control after repeated cycles. That imperfect result deserves investigation, not marketing language.
| Dimension | Key Point | Definition, Principle, or Typical Data |
|---|---|---|
| Definition | Robots made from compliant materials | Soft robotics is a field of robotics that designs machines using flexible, elastic, or deformable materials. Instead of relying only on rigid links and conventional joints, soft robots use controlled deformation to move, interact, and perform tasks. |
| Core Mechanical Principle | Movement through deformation | Soft structures bend, stretch, twist, compress, or inflate when forces are applied. Their motion results from the interaction between material elasticity, geometry, external loads, and actuator input. |
| Common Materials | Elastomers, rubbers, textiles, and flexible composites | Frequently used material groups include silicone elastomers, natural or synthetic rubber, thermoplastic elastomers, fabric-reinforced structures, flexible polymers, hydrogels, and compliant composite materials. |
| Pneumatic Actuation | Motion generated by air pressure | Flexible chambers or channels expand when pressurized. Different chamber shapes and pressure levels can produce bending, elongation, contraction, or gripping. Pneumatic systems are widely used because they can create large deformation with relatively low structural stiffness. |
| Hydraulic Actuation | Motion generated by fluid pressure | An incompressible liquid is pumped into flexible chambers to create force and deformation. Hydraulic actuation can provide smooth motion and high force density, but it usually requires fluid containment and additional pumping equipment. |
| Cable-Driven Actuation | Tension transmitted through tendons or cables | Pulling a cable attached to a compliant body causes the body to bend or move. This approach can place motors away from the deformable structure, reducing the mass at the moving section. |
| Shape-Memory Actuation | Shape change caused by temperature | Shape-memory alloys and other thermally responsive materials can contract or return toward a programmed shape when heated. Their main limitations are relatively slow cooling and reduced efficiency compared with some other actuation methods. |
| Electroactive Actuation | Deformation caused by an electric field | Dielectric elastomers, ionic polymer materials, and related technologies can deform in response to electrical stimulation. These actuators can be lightweight and compact, although they may require high voltage or careful electrical design. |
| Sensing | Measurement of shape, force, pressure, and contact | Soft robots may use flexible resistive, capacitive, optical, magnetic, fluidic, or piezoresistive sensors. Sensors can be embedded into the body to estimate curvature, contact force, internal pressure, strain, or the robot's interaction with its environment. |
| Control Method | Closed-loop control under changing body shapes | Controllers combine actuator commands with sensor feedback. Because soft bodies have many degrees of freedom and nonlinear behavior, control often uses simplified physical models, data-driven models, proprioceptive sensing, or hybrid model-based and experimental methods. |
| Compliance | Ability to yield under external force | Compliance allows a soft robot to conform to objects, absorb impacts, and reduce the risk of damage during contact. The same compliance can make precise positioning and repeatable motion more difficult than in rigid robots. |
| Degrees of Freedom | Distributed and often continuous motion | A deformable body can produce motion across its entire length rather than only at a few discrete joints. This creates rich movement capabilities but also makes the robot's exact configuration harder to measure and model. |
| Gripping Principle | Conforming contact and distributed force | Soft grippers can wrap around objects with different shapes and sizes. Their deformable fingers distribute contact forces over a larger area, which is useful for fragile, irregular, or easily damaged items. |
| Safety Characteristic | Lower mechanical impact risk in many interactions | Low stiffness and lightweight structures can reduce collision forces during physical contact. Safety still depends on actuator pressure, speed, stored energy, control quality, and the specific design of the robot. |
| Main Advantages | Adaptability, lightweight construction, and safe contact | Typical advantages include the ability to handle uncertain objects, navigate confined spaces, absorb impacts, conform to surfaces, and perform delicate manipulation with relatively simple mechanical structures. |
| Main Limitations | Modeling difficulty, wear, and limited precision | Challenges include nonlinear deformation, hysteresis, material fatigue, air or fluid leakage, limited load capacity in some designs, slower response for certain actuators, and difficulty achieving highly repeatable positioning. |
| Manufacturing Methods | Molding, casting, lamination, and additive fabrication | Soft components are commonly produced through elastomer molding, layered fabrication, textile reinforcement, embedded-channel manufacturing, laser processing, and additive manufacturing. The selected method affects durability, precision, and the ability to integrate sensors or actuators. |
| Typical Applications | Manipulation, medical devices, exploration, and wearable systems | Applications include delicate object handling, minimally invasive tools, rehabilitation devices, wearable assistive systems, agricultural handling, underwater or confined-space exploration, adaptive grippers, and research platforms for human-robot interaction. |
| Performance Measures | Force, displacement, speed, pressure, accuracy, and durability | Evaluation commonly considers payload or output force, range of motion, bending angle, response time, pressure or power requirements, positioning error, repeatability, energy efficiency, cycle life, and resistance to puncture or fatigue. |
| Best-Suited Tasks | Tasks involving uncertainty, contact, or delicate objects | Soft robots are especially suitable when objects vary in shape, the environment is unstructured, contact is unavoidable, or rigid mechanisms could cause damage. Rigid robots may remain preferable for high-speed, high-load, and highly precise repetitive operations. |
Note: Performance values depend on the actuator type, material formulation, geometry, manufacturing process, and control system used in a specific soft-robot design.